 NIRMIO
Project 7: Arduino/PLC-Controlled Pneumatic Sorting Station
Automatically sort objects by size, material or colour, and measure cycle time and sorting accuracy...
View project and guideProjects / Mechanical / Project 57
Approx. component budget: Rs. 5,000 - 9,000
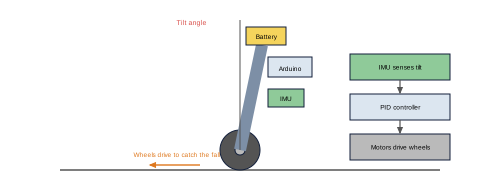
Make the robot balance itself and find how PID gains, wheel size and weight position change its stability.
A two-wheel robot with geared motors, an MPU6050 IMU, a motor driver and an Arduino/ESP32 running a PID controller, on a light frame with a battery.
The inverted pendulum, PID control and sensors, the basics of control in mechatronics.
Arduino/ESP32, MPU6050, Python or Excel plots. Needs patience for tuning. Test on a smooth floor.
Replace [x] with your own measured results. Write only what you really did.
A short guide that helps you decide and prepare. It contains:
We send the PDF on WhatsApp after your payment is confirmed. Payment details are shared in the chat.
Automatically sort objects by size, material or colour, and measure cycle time and sorting accuracy...
View project and guideBuild the rover and test its ability to climb steps and slopes, and compare it with a rigid four-wheel chassis...
View project and guideBuild a robot that crawls inside pipes and measure its traction, climbing angle and speed...
View project and guide