 NIRMIO
Project 5: Vibration Analysis and Condition Monitoring of a Rotating Shaft
Detect unbalance, misalignment and bearing faults from the vibration spectrum of a small rotating shaft...
View project and guideProjects / Mechanical / Project 39
Approx. component budget: Rs. 6,000 - 11,000
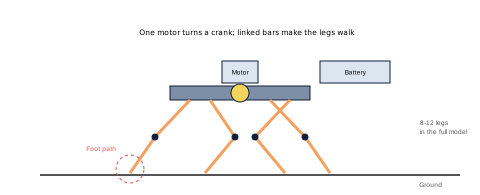
Build the linkage and find which link lengths give the best step length and smoothest walk, and measure speed and battery use.
A Theo Jansen type multi-link walking frame with 8-12 legs, laser-cut or 3D-printed links, a small geared motor and a battery pack.
Linkage synthesis, kinematic simulation, link optimisation and legged robot design.
Free mechanism simulators, 3D printing or acrylic cutting, Arduino or a simple RC. No special lab needed.
Replace [x] with your own measured results. Write only what you really did.
A short guide that helps you decide and prepare. It contains:
We send the PDF on WhatsApp after your payment is confirmed. Payment details are shared in the chat.
Detect unbalance, misalignment and bearing faults from the vibration spectrum of a small rotating shaft...
View project and guideReduce the weight of a bracket while keeping similar stiffness and strength, and check the computer (FEA) resu...
View project and guideDesign a robotic arm for a target payload, derive its kinematics, and measure repeatability and maximum payloa...
View project and guide