 NIRMIO
Project 5: Vibration Analysis and Condition Monitoring of a Rotating Shaft
Detect unbalance, misalignment and bearing faults from the vibration spectrum of a small rotating shaft...
View project and guideProjects / Mechanical / Project 8
Approx. component budget: Rs. 10,000 - 15,000
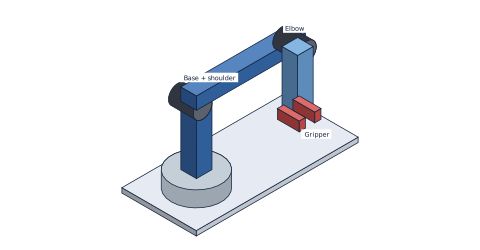
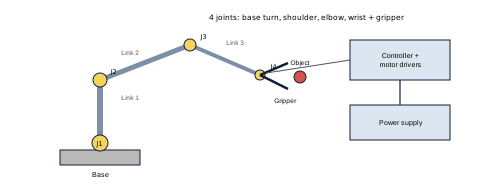
Design the arm for a target payload, derive forward and inverse kinematics, and measure repeatability and maximum payload.
Links in aluminium/acrylic/3D-printed parts, high-torque servos or steppers, controller, motor drivers, power supply and a gripper.
Robotics, kinematics and mechanism design. Good for automation and robotics interviews.
Arduino/ESP32, Python or MATLAB for kinematics.
Replace [x] with your own measured results. Write only what you really did.
A short guide that helps you decide and prepare. It contains:
We send the PDF on WhatsApp after your payment is confirmed. Payment details are shared in the chat.
Detect unbalance, misalignment and bearing faults from the vibration spectrum of a small rotating shaft...
View project and guideReduce the weight of a bracket while keeping similar stiffness and strength, and check the computer (FEA) resu...
View project and guideCompare the measured follower displacement and jump behaviour of different cam profiles with theory...
View project and guide